> For the complete documentation index, see [llms.txt](https://support.powerio.com/hub/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://support.powerio.com/hub/codesys-hvac/en/hvac-library/functionblocks/components/valve3p.md).
# Valve3P
## `Valve3P` (FB)
FUNCTION\_BLOCK Valve3P
### Short description
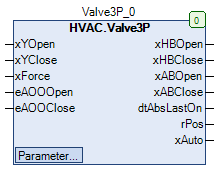
> Control of a 3-point valve actuator and calculation of the valve position\
> In addition, the 3-point actuator is protected by an anti-blocking function.\
> Typical application: Control of a 3-point valve actuator in a heating circuit
### Representation
### Interfaces
#### Inputs
| Name | Data type | Value range | Initial value | Function |
| ----------- | ----------------- | ------------------------------------------------------------------------- | ------------- | ------------------------------------------------- |
| *xYOpen* | BOOL | | | Control signal - valve opening |
| *xYClose* | BOOL | | | Control signal - valve closing |
| *xForce* | BOOL | | FALSE | Forced override after manual override |
| *xAlarmIn* | BOOL | | FALSE | Actuator fault message |
| *eAOOOpen* | HVACTYPES.eManBin | HVACTYPES.eManBin.Auto, HVACTYPES.eManBin.ManOff, HVACTYPES.eManBin.ManOn | | Manual override mode - hardware for valve opening |
| *eAOOClose* | HVACTYPES.eManBin | HVACTYPES.eManBin.Auto, HVACTYPES.eManBin.ManOff, HVACTYPES.eManBin.ManOn | | Manual override mode - hardware for valve closing |
#### Outputs
| Name | Data type | Value range | Initial value | Function |
| ------------- | --------------- | ----------- | ------------- | ------------------------------------------------------- |
| *xHBOpen* | BOOL | | | Enable - valve opening after manual override |
| *xHBClose* | BOOL | | | Enable - valve closing after manual override |
| *xABOpen* | BOOL | | | Enable - valve opening before manual override |
| *xABClose* | BOOL | | | Enable - valve closing before manual override |
| *dtAbsLastOn* | DATE\_AND\_TIME | | | Start date/time of the last blocking protection process |
| *rPos* | REAL | 0.0 … 100.0 | | Calculated current valve position |
| *xAuto* | BOOL | | | Collective automatic operation message |
#### Setpoints / Parameters
| Name | Data type | Value range | Initial value | Function |
| ------------------- | --------- | ------------------------------------- | ------------- | --------------------------------------------------------------- |
| **tDuration** | TIME | | 120s | Actuator running time |
| **udiAbsTime** | UDINT | 0 to 3600s | 200s | Duration of the blocking protection process |
| **todAbsStartTime** | TOD | | TOD#09:00:00 | Start time of the blocking protection process |
| **eAbsDay** | eDoW | | eDow\.Monday | Weekday of the blocking protection process |
| **xForceOption** | BOOL | | TRUE | Status of outputs *xHBOpen* or *xHBClose* under forced override |
| **eManModeOpen** | eMANBIN | eMANBIN.Auto, eMANBIN.Off, eMANBIN.On | eMANBIN.Auto | Manual override mode - valve opening |
| **eManModeClose** | eMANBIN | eMANBIN.Auto, eMANBIN.Off, eMANBIN.On | eMANBIN.Auto | Manual override mode - valve closing |
### Functional description
#### General
This function block is used to control the position of a 3-point valve actuator via the outputs Enable - valve opening after manual override *xHBOpen* or *xHBClose*.\
The current valve position is continuously calculated and is available at the output *rPos* is available.\
The following function blocks are mainly used:
* Abs3P
* ManBin
* Position3P
#### Anti-blocking protection process
This process is implemented by monitoring signals 1 and 2 for activity and, if necessary, by triggering the anti-blocking function.\
The test period is 168 hours each time (= 1 week).\
Signals 1 and 2 are active if they are continuously active during the test period for the minimum operating time of 30.0 s (signal 1 only or signal 2 only or both).\
The anti-blocking process is thereby prevented, the test period starts again.\
\
Signal 1: (*xYOpen* AND *eAOOOpen* = HVACTYPES.eManBin.Auto) OR (eAOOOpen = HVACTYPES.eManBin.ManOn)\
\
Signal 2: (*xYClose* AND *eAOOClose* = HVACTYPES.eManBin.Auto) OR (eAOOClose = HVACTYPES.eManBin.ManOn)\
\
If no activity is detected during the test period, the anti-blocking process is triggered on the weekday **eAbsDay** at the time **todAbsStartTime** triggered.\
At the same time, the test period starts again.\
\
The active anti-blocking process is divided into two consecutive time sections (section 1 and section 2).\
In section 1, during the time period **udiAbsTime** the combination Enable - output *xABOpen* = TRUE, Enable - output *xABClose* = FALSE is output.\
In section 2, during the time period **udiAbsTime** the combination Enable - output *xABOpen* = FALSE, Enable - output *xABClose* = TRUE is output.\
\
The initial triggering of the anti-blocking process can, depending on the relevant settings (weekday **eAbsDay** and **todAbsStartTime**) be delayed.
> **Example**
>
> Test period ended on Tuesday morning, triggering of the blocking protection process only on the following Monday.
\
At output *dtAbsLastOn* the start date and start time of the last blocking protection process are available.
> **Prerequisite for using the function block Abs3P**
>
> For correct operation, the use of the TimeRead2 function block is required.
#### Enable - valve opening before manual override *xABOpen*
The Enable - valve opening before manual override *xABOpen* is controlled by the input Request - valve opening *xYOpen* and the anti-blocking protection module.
| *xYOpen* | Anti-blocking protection process | *xABOpen* | Notes |
| -------- | -------------------------------- | -------------------------------- | -------------------------------------------- |
| FALSE | FALSE | FALSE | Request not active, no anti-blocking process |
| X | TRUE | Section 1: TRUE Section 2: FALSE | Blocking protection process active |
| TRUE | FALSE | TRUE | Request active, no anti-blocking process |
Legend: X = any
#### Enable - valve closing before manual override *xABClose*
The Enable - valve closing before manual override *xABClose* is controlled by the input\
Request - valve closing *xYClose* and the anti-blocking protection module.
| *xYClose* | Anti-blocking protection process | *xABClose* | Notes |
| --------- | -------------------------------- | -------------------------------- | -------------------------------------------- |
| FALSE | FALSE | FALSE | Request not active, no anti-blocking process |
| X | TRUE | Section 1: FALSE Section 2: TRUE | Blocking protection process active |
| TRUE | FALSE | TRUE | Request active, no anti-blocking process |
Legend: X = any
#### Enable - valve opening after manual override *xHBOpen*
The Enable - valve opening after manual override *xHBOpen* corresponds to the Enable - valve opening before manual override *xABOpen* additionally extended by a manual override module and a forced override.
| *xABOpen* | **eManModeOpen** | *xForce* | **xForceOption** | *xHBOpen* | Notes |
| --------- | ---------------- | -------- | ---------------- | --------- | ----------------------------------------- |
| FALSE | eMANBIN.Auto | FALSE | X | FALSE | Manual override module in automatic mode |
| TRUE | eMANBIN.Auto | FALSE | X | TRUE | Manual override module in automatic mode |
| X | eMANBIN.On | FALSE | X | TRUE | Manual override module in manual mode On |
| X | eMANBIN.Off | FALSE | X | FALSE | Manual override module in manual mode Off |
| X | X | TRUE | FALSE | FALSE | Forced override Close |
| X | X | TRUE | TRUE | TRUE | Forced override Open |
Legend: X = any
#### Enable - valve closing after manual override *xHBClose*
The Enable - valve closing after manual override *xHBClose* corresponds to the Enable - valve closing before manual override *xABClose* additionally extended by a manual override module and a forced override.
| *xABClose* | **eManModeOpen** | *xForce* | **xForceOption** | *xHBClose* | Notes |
| ---------- | ---------------- | -------- | ---------------- | ---------- | ----------------------------------------- |
| FALSE | eMANBIN.Auto | FALSE | X | FALSE | Manual override module in automatic mode |
| TRUE | eMANBIN.Auto | FALSE | X | TRUE | Manual override module in automatic mode |
| X | eMANBIN.On | FALSE | X | TRUE | Manual override module in manual mode On |
| X | eMANBIN.Off | FALSE | X | FALSE | Manual override module in manual mode Off |
| X | X | TRUE | FALSE | FALSE | Forced override Close |
| X | X | TRUE | TRUE | TRUE | Forced override Open |
Legend: X = any
#### Forced control of the manual overrides of the outputs
If the manual override mode - valve opening is **eManModeOpen** in state eMANBIN.On (= manual override opening active), then the manual override mode - valve closing is forcibly **eManModeClose** set to state eMANBIN.Off (= manual override closing not active).\
\
If the manual override mode - valve closing is **eManModeClose** in state eMANBIN.On (= manual override closing active), then the manual override mode - valve opening is forcibly **eManModeOpen** set to state eMANBIN.Off (= manual override opening not active).
#### Current valve position *rPos*
It is used to display the current position of the 3-point actuator in the range 0 - 100% and is calculated from the duration of the signals at the outputs Enable - valve opening after manual override *xHBOpen* and Enable - valve closing after manual override *xHBClose* in combination with the actuator running time **tDuration** calculated.\
\
The position display is independent of signal generation, i.e. if the position display reaches an end position (0% or 100%), signals are still continued at the outputs *xABOpen* and *xABClose* or *xHBOpen* and *xHBClose* generated.\
The position display does not take into account any position changes caused by the manual override - hardware.
#### Collective fault *xAlarm*
The collective fault *xAlarm* is activated (= TRUE) if the input *xAlarmIn* is active.\
In all other cases the collective fault is *xAlarm* is not activated (= FALSE).
#### Collective automatic operation message *xAuto*
The collective automatic operation message *xAuto* is activated (= TRUE) if the following conditions are simultaneously met:
* Input *eAOOUp* = HVACTYPES.eManBin.Auto
* Input *eAOODown* = HVACTYPES.eManBin.Auto
* Setpoint / parameter **eManModeUp** = eMANBIN.Auto
* Setpoint / parameter **eManModeDown** = eMANBIN.Auto
#### Forced override *xForce*
The forced override acts directly on the outputs *xHBOpen* and *xHBClose*. With the parameter **xForceOption** it is determined which state the output *xHB* assumes when TRUE is at the input *xForce* takes.\
\
With **xForceOption** = FALSE\
If the input *xForce* is TRUE, then the output *xHBOpen* to FALSE and at the same time the output *xHBClose* is set to TRUE.\
\
When **xForceOption** = TRUE\
If the input *xForce* is TRUE, then the output *xHBOpen* to TRUE and at the same time the output *xHBClose* is set to FALSE.
### CODESYS
InOut:
| Scope | Name | Type | Initial |
| ----------- | ----------------- | ------- | ----------------- |
| Input | `xYOpen` | `BOOL` | |
| Input | `xYClose` | `BOOL` | |
| Input | `xForce` | `BOOL` | FALSE |
| Input | `xAlarmIn` | `BOOL` | FALSE |
| Input | `eAOOOpen` | eManBin | |
| Input | `eAOOClose` | eManBin | |
| Output | `xHBOpen` | `BOOL` | |
| Output | `xHBClose` | `BOOL` | |
| Output | `xABOpen` | `BOOL` | |
| Output | `xABClose` | `BOOL` | |
| Output | `dtAbsLastOn` | `DT` | |
| Output | `rPos` | `REAL` | |
| Output | `xAlarm` | `BOOL` | |
| Output | `xAuto` | `BOOL` | |
| Input Const | `udiDuration` | `UDINT` | 120 |
| Input Const | `udiAbsTime` | `UDINT` | 200 |
| Input Const | `todAbsStartTime` | `TOD` | TIME\_OF\_DAY#9:0 |
| Input Const | `eAbsDay` | eDoW | eDow\.Monday |
| Input Const | `xForceOption` | `BOOL` | TRUE |
| Input Const | `eManModeOpen` | eMANBIN | eMANBIN.Auto |
| Input Const | `eManModeClose` | eMANBIN | eMANBIN.Auto |
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://support.powerio.com/hub/codesys-hvac/en/hvac-library/functionblocks/components/valve3p.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.