> For the complete documentation index, see [llms.txt](https://support.powerio.com/hub/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://support.powerio.com/hub/codesys-hvac/en/hvac-library/functionblocks/components/valve2p.md).
# Valve2P
## `Valve2P` (FB)
FUNCTION\_BLOCK Valve2P
### Short description
> Control of a binary valve actuator with two position feedback signals\
> \
> Typical application: Actuator for a boiler system with shut-off dampers
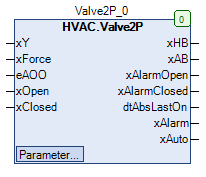
### Representation
### Interfaces
#### Inputs
| Name | Data type | Value range | Initial value | Function |
| ---------- | ----------------- | ------------------------------------------------------------------------- | ---------------------- | ------------------------------------------------ |
| *xY* | BOOL | | | Control signal |
| *xForce* | BOOL | | FALSE | Forced override after manual override |
| *xAlarmIn* | BOOL | | FALSE | Actuator fault message |
| *eAOO* | HVACTYPES.eManBin | HVACTYPES.eManBin.Auto, HVACTYPES.eManBin.ManOff, HVACTYPES.eManBin.ManOn | HVACTYPES.eManBin.Auto | Operating mode of the manual override - hardware |
| *xOpen* | BOOL | | | Valve open feedback |
| *xClosed* | BOOL | | | Valve closed feedback |
#### Outputs
| Name | Data type | Value range | Initial value | Function |
| -------------- | --------------- | ----------- | ------------- | ----------------------------------------------- |
| *xHB* | BOOL | | | Enable valve actuator after manual override |
| *xAB* | BOOL | | | Enable valve actuator before manual override |
| *xAlarmOpen* | BOOL | | | Fault position valve open |
| *xAlarmClosed* | BOOL | | | Fault position valve closed |
| *dtAbsLastOn* | DATE\_AND\_TIME | | | Date / time of the last anti-blocking operation |
| *xAlarm* | BOOL | | | Collective fault |
| *xAuto* | BOOL | | | Collective automatic operation message |
#### Setpoints / Parameters
| Name | Data type | Value range | Initial value | Function |
| ------------------- | --------- | ------------------------------------------- | ------------- | ------------------------------------------------------------------ |
| **udiAbsTime** | UDINT | 0 … 600s | 200s | Duration of the anti-blocking operation |
| **todAbsStartTime** | TOD | 00:00:00 - 23:59:59 | 09:00:00 | Time of the anti-blocking operation |
| **eAbsDay** | eDoW | eDow\.Inactive, eDoW\.Monday … eDoW\.Sunday | eDoW\.Monday | Day of the week of the anti-blocking operation |
| **udiControlTime** | UDINT | 10s … 600s | 150s | Signal delay of position monitoring |
| **xControl** | BOOL | | TRUE | Enable position monitoring |
| **xForceOption** | BOOL | | FALSE | State of the output *xHB* under forced override |
| **eManModeB** | eMANBIN | eMANBIN.Auto, eMANBIN.ManOff, eMANBIN.ManOn | eMANBIN.Auto | Operating mode of the manual override for the digital output *xHB* |
### Functional description
#### Automatic output *xAB*
The enable of the valve actuator before manual override *xAB* is passed through unchanged from the enable input *xY* .
#### Manual output *xHB*
The enable of the valve actuator after manual override *xHB* corresponds to the enable of the valve actuator before manual override *xAB* additionally extended by a manual override module and a forced override.
| *xAB* | **eManModeB** | *xForce* | **xForceOption** | *xHB* | Notes |
| ----- | -------------- | -------- | ---------------- | ----- | ----------------------------------------- |
| FALSE | eMANBIN.Auto | FALSE | X | FALSE | Manual override module in automatic mode |
| TRUE | eMANBIN.Auto | FALSE | X | TRUE | Manual override module in automatic mode |
| X | eMANBIN.ManOff | FALSE | X | FALSE | Manual override module in manual mode Off |
| X | eMANBIN.ManOn | FALSE | X | TRUE | Manual override module in manual mode On |
| X | X | TRUE | FALSE | FALSE | Forced override Close |
| X | X | TRUE | TRUE | TRUE | Forced override Open |
Legend: X = any
#### Fault position valve open *xAlarmOpen*
The fault message for the position at valve opening *xAlarmOpen* is activated\
(*xAlarmOpen* = TRUE), if the following conditions are simultaneously met:
1\) The enable of position monitoring *xControl* is enabled (= TRUE)\
\
2\) As operating mode of the manual override - hardware \*eAOO\*, automatic mode is selected (eAOO = HVACTYPES.eManBin.Auto)\
\
3\) The states of the enable of the valve actuator after manual override xHB and the feedback for valve opening xOpen are continuously different for at least the signal delay of position monitoring udiControlTime ((xHB = FALSE and xOpen = TRUE) OR (xHB = TRUE and xOpen = FALSE)).\
\
The fault message for the valve opening position xAlarmOpen is deactivated if at least one of the above conditions is no longer met.
#### Fault position valve open *xAlarmClosed*
The fault message for the position at valve opening *xAlarmClosed* is activated (*xAlarmClosed* = TRUE), if the following conditions are simultaneously met:
1\) The enable of position monitoring *xControl* is enabled (= TRUE)\
\
2\) As operating mode of the manual override - hardware eAOO, automatic mode is selected (eAOO = HVACTYPES.eManBin.Auto)\
\
3\) The states of the enable of the valve actuator after manual override xHB and the feedback for valve closing xClosed are continuously identical for at least the signal delay of position monitoring udiControlTime ((xHB = TRUE and xOpen = TRUE) OR (xHB = FALSE and xOpen = FALSE)).\
\
The fault message for the valve opening position xAlarmClosed is deactivated if at least one of the above conditions is no longer met.
#### Collective fault *xAlarm*
The collective fault *xAlarm* is activated (= TRUE) if at least one of the two faults for the damper positions (*xAlarmOpen* and *xAlarmClosed*) or the input *xAlarmIn* is active.\
In all other cases, the collective fault *xAlarm* is not activated (= FALSE).
#### Anti-blocking protection module
The anti-seizing protection module is implemented by the binary anti-seizing protection module with adjustable duration (FB: AbsB).\
The duration *udiAbsTime*, the time **todAbsStartTime** and the weekday **eAbsDay** can be adjusted.\
The minimum run time for blocking the anti-seizing operation is 30 s.\
The timestamp (date / time) of the last anti-seizing operation *dtAbsLastOn* is available.
#### Collective automatic operation message *xAuto*
The collective automatic operation message *xAuto* is activated (= TRUE) if the input *eAOO* contains the value HVACTYPES.eManBin.Auto and the setpoint / parameter **eManModeB** contains the value eMANBIN.Auto.\
In all other cases, the collective automatic operation message *xAuto* is not activated (= FALSE).
#### Forced override *xForce*
The forced override acts directly on the output *xHB*. With the parameter **xForceOption** it is determined which state the output *xHB* assumes when TRUE is at the input *xForce* .
### CODESYS
InOut:
| Scope | Name | Type | Initial |
| ----------- | ----------------- | ------- | ----------------- |
| Input | `xY` | `BOOL` | |
| Input | `xForce` | `BOOL` | FALSE |
| Input | `xAlarmIn` | `BOOL` | FALSE |
| Input | `eAOO` | eManBin | eManBin.Auto |
| Input | `xOpen` | `BOOL` | |
| Input | `xClosed` | `BOOL` | |
| Output | `xHB` | `BOOL` | |
| Output | `xAB` | `BOOL` | |
| Output | `xAlarmOpen` | `BOOL` | |
| Output | `xAlarmClosed` | `BOOL` | |
| Output | `dtAbsLastOn` | `DT` | |
| Output | `xAlarm` | `BOOL` | |
| Output | `xAuto` | `BOOL` | |
| Input Const | `udiAbsTime` | `UDINT` | 120 |
| Input Const | `todAbsStartTime` | `TOD` | TIME\_OF\_DAY#8:0 |
| Input Const | `eAbsDay` | eDoW | eDow\.Monday |
| Input Const | `udiControlTime` | `UDINT` | 200 |
| Input Const | `xControl` | `BOOL` | TRUE |
| Input Const | `xForceOption` | `BOOL` | FALSE |
| Input Const | `eManModeB` | eMANBIN | eMANBIN.Auto |
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://support.powerio.com/hub/codesys-hvac/en/hvac-library/functionblocks/components/valve2p.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.